Allen the PR2
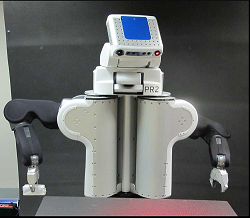
Allen the PR2 is a mobile manipulation platform developed by Willow Garage. The robot has two 7-degree-of-freedom arms for manipulating objects and an omni-directional base for navigation. It carries an array of sensors including two Hokuyo laser range finders and seven cameras for building 3-D maps of its surroundings and identifying objects. In our lab we use Allen to test a variety of planners including single-arm, dual-arm, navigation (in position and orientation), and full-body mobile manipulation.
Man-Hack the Hexacopter
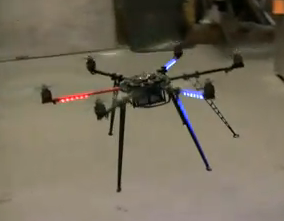
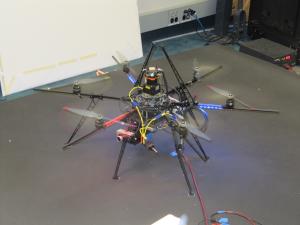
Man-Hack the Hexacopter is our lab unmanned aerial vehicle (UAV). The base is a Mikrokopter Hexa XL frame with a custom-made carbon fiber computer carrier and blade guard. Onboard processing is performed by an i7 COM Express module running ROS, allowing the hexacopter to operate without any off-board connectivity. Like Melvin, it uses two orthogonally mounted Hokuyo laser range finders as the primary localization sensors, augmented by GPS and two wide-angle camera systems. Total system weight is approximately 4.3 kg with over 15 minutes of flight time.
The hexacopter is used for 3-D planning research including planning under uncertainty, planning in the presence of 3-D dynamic obstacles, and visual servoing in conjunction with planning.
Melvin the Segbot
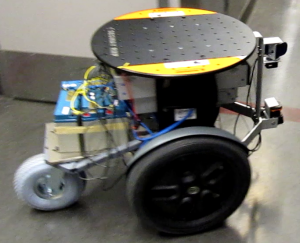
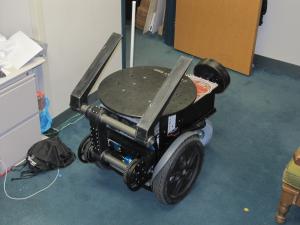
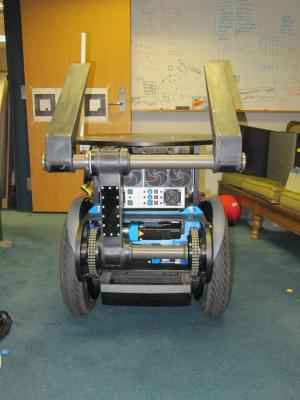
Melvin the Segbot is based on a Segway RMP 200 platform with a custom-made rear trailer allowing it to operate in a variety of environments both indoors and outdoors. The custom computer system consists of an 8-core server and a 2-core controller, giving Melvin the highest computational capability of any of our lab robots. Like all of our robots, Melvin uses ROS running on Kubuntu for the software infrastructure. For sensing the environment, Melvin relies on two Hokuyo laser range finders, supplemented by GPS or vision systems when required.
Melvin is used primarily for ground navigation research, including research in exploration, planning in the presence of dynamic obstacles, and multi-robot planning.
This page describes the hardware platforms used during the sbpl.net era of the lab (~2012–2015). For the lab’s current robotic platforms, see the People page and recent publications.